The idea
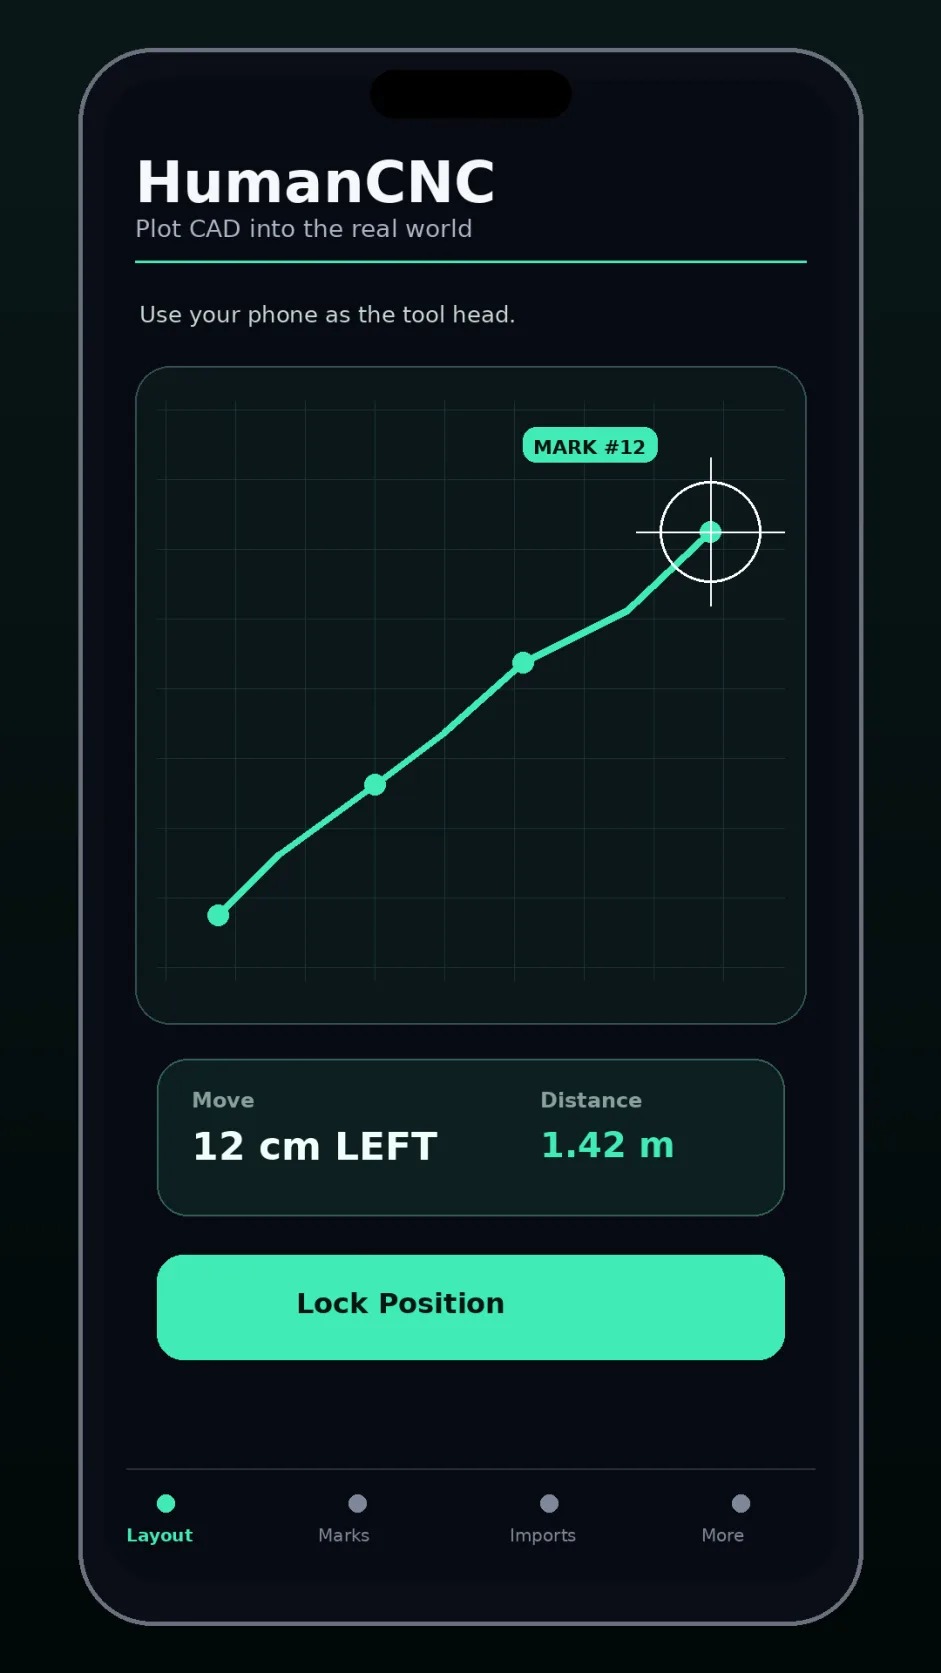
Use temporary phone anchors and a tracked tool phone to guide a person toward a chair, stage mark, picture position, or CAD coordinate with haptic cues.
How it works
- Place temporary phones at known reference points and visually calibrate a shared coordinate frame.
- Track the tool phone against the calibrated references as the person moves.
- Change haptic cues as the person approaches the target and signal arrival.
AI’s role: Translate a target or task into simple guidance; shared visual calibration and measured tracking establish the coordinate frame and must be checked independently.
First demonstration
Mark several chair positions in a room, guide a person to each with a tracked phone, and independently measure the final position error.
What to solve next
What practical position error remains after calibration as phones move, visual tracking changes, and the person walks between anchors?