The idea
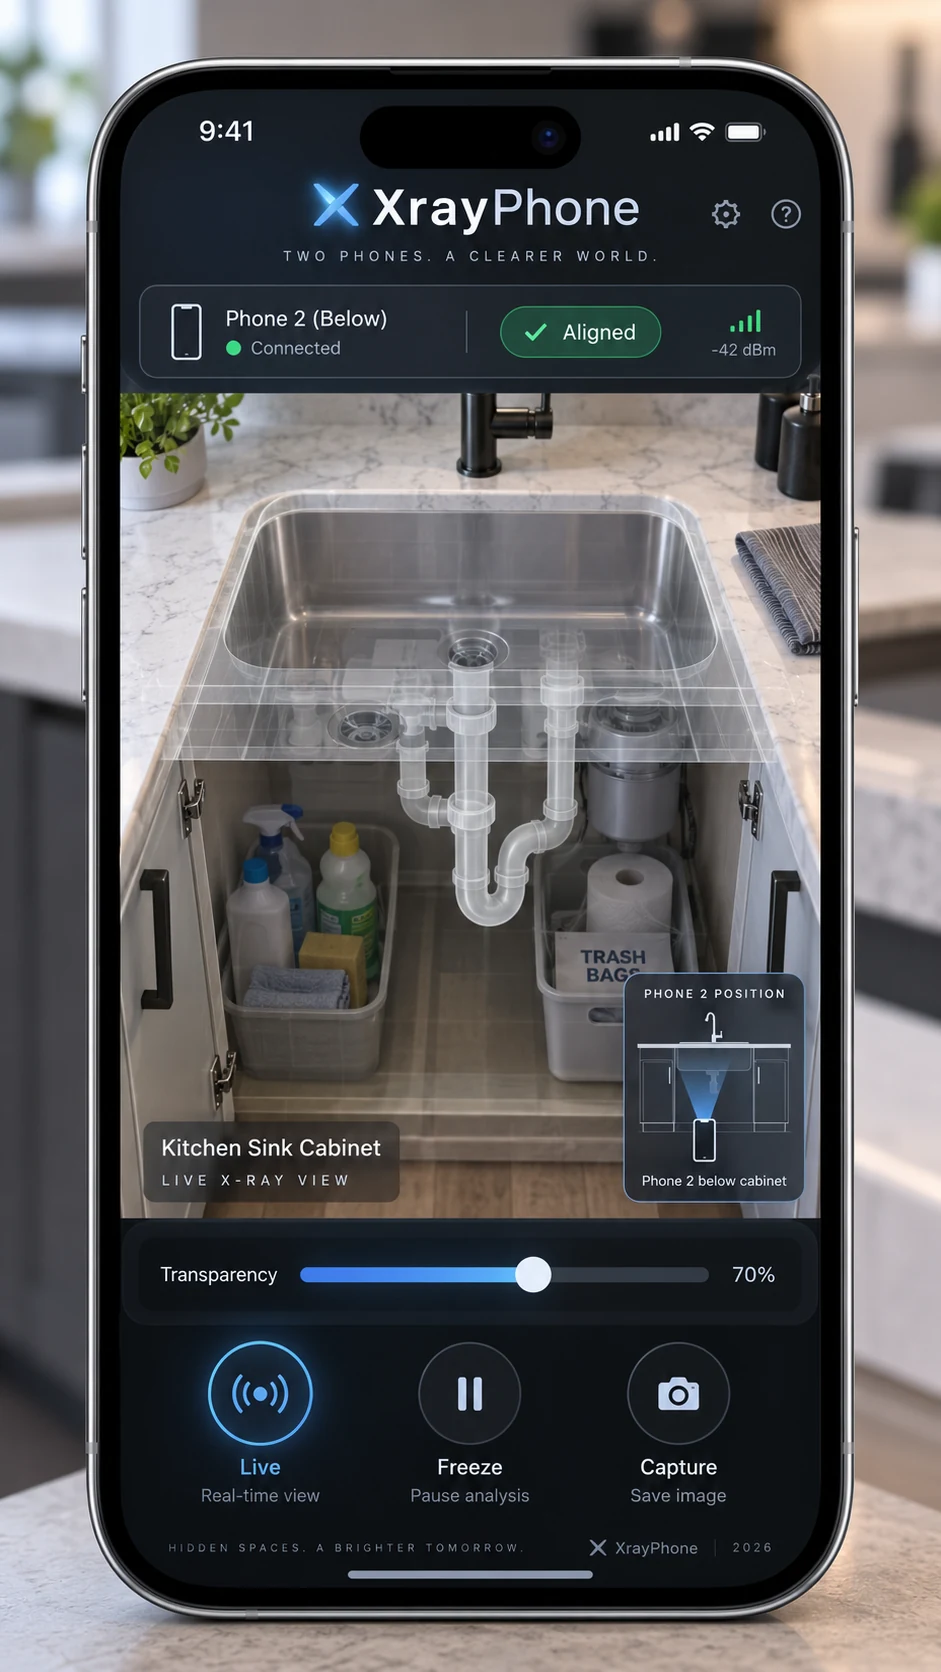
Place one phone behind or beneath an object and use another to align its live camera view with the space in front of you.
How it works
- A remote phone streams a real camera view from behind or beneath an object.
- The viewing phone aligns that image into the scene using shared spatial coordinates and supported ranging.
- The view can help inspect sink pipes, a car part, or something dropped beneath furniture; it does not see through solid material.
AI’s role: Recognize the object or work area and help interpret the request. Spatial alignment and camera geometry must be handled by measured tracking, not AI intuition.
First demonstration
Put a phone under a sink and align its live view with the camera phone above. Move the viewing phone and confirm the remote image stays registered to the real scene.
What to solve next
How will two independently held phones establish a stable shared camera pose in a cramped, reflective space?